# LidarView - Add an Extra Lidar Frame in Pipeline
**URL:** https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201
**Category:** LidarView, Lidar, and SLAM
**Created:** [November 7, 2023, 7:32am UTC](https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201 "2023-11-07T07:32:26Z")
**Posts on this page:** 4
**Page:** 1
### Author:  [@Raj1](https://discourse.paraview.org/u/Raj1)
#### Post date: [November 7, 2023, 7:32am UTC](https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201/1 "2023-11-07T07:32:26Z")
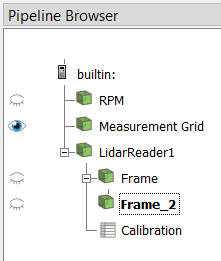
Hi all, I am new to lidarview development. I want a add a extra Frame in pipeline for my custom lidar which is using modified velodyne interpreter & it provides 2 set of point cloud data, Now i want to add extra **Frame** data in order to show second point cloud data. similar to below image. Any suggestions on how to implement ?
---
### Author:  [@nicolas.vuaille](https://discourse.paraview.org/u/nicolas.vuaille)
#### Post date: [November 7, 2023, 12:23pm UTC](https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201/2 "2023-11-07T12:23:17Z")
@Timothee_Couble ?
---
### Author:  [@Timothee\_Couble](https://discourse.paraview.org/u/Timothee_Couble)
#### Post date: [November 8, 2023, 9:58am UTC](https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201/3 "2023-11-08T09:58:20Z")
Hi @Raj1,
To incorporate a second Frame into the pipeline, you’ll have to modify the `vtkLidarReader` class by adding a second output to the vtk filter and updating the associated XML file `LidarReader.xml`. Afterwards, you’ll need to develop a new `vtkLidarPacketInterpreter` capable of handling two frames instead of just one. Keep in mind that these classes were initially designed to work with a single Frame, so this task may not be straightforward.
Another approach to achieving this, could be to modify your interpreter by introducing a scalar value that specifies which frame each point belongs to. Then, you can either create a new filter or utilize the Threshold filter to segment the point cloud based on that scalar value.
Hope this helps,
Timothée
---
### Author:  [@Raj1](https://discourse.paraview.org/u/Raj1)
#### Post date: [November 9, 2023, 8:32am UTC](https://discourse.paraview.org/t/lidarview-add-an-extra-lidar-frame-in-pipeline/13201/4 "2023-11-09T08:32:39Z")
Thanks @Timothee_Couble